> For the complete documentation index, see [llms.txt](https://docs.petoi.com/llms.txt). Markdown versions of documentation pages are available by appending `.md` to page URLs; this page is available as [Markdown](https://docs.petoi.com/mobile-app/app-guide/bittle-x+arm.md).
# Bittle X+Arm
The calibrator interface for Bittle X+Arm is as follows:
{% hint style="info" %}
The interfaces above will be displayed when you calibrate for the first time. You can also click to open the upper-right menu in the control panel and select **Calibrate** to re-access.\

{% endhint %}
**For the** pre-assembled kit, you can directly power on the robot and use the mobile app to fine-tune all joints.
**For the construction kit, after** the robot enters the calibration state, do the following steps:
### Install the neck servo and leg servos
{% hint style="info" %}
Note:
You must use the neck section with a J-hook (as pictured below) to avoid the neck from falling when using this robot arm.

{% endhint %}
Installing the neck servo is the same as [installing the head](/mobile-app/app-guide/bittle.md#install-the-head) of Bittle.
Installing the leg servos is the same as [installing the legs](/mobile-app/app-guide/bittle.md#install-the-legs) of Bittle.
### Install the robot arm
This robot arm is already fully assembled. After finishing calibrating the neck servo and the leg servos, power off the robot and [install](/extensible-modules/robot-arm.md#installation) the servo slot on the neck servo with two M2\*5 self-tapping screws.
Then, power on the robot, and do the joint calibration for the servos on the robot arm.
---
# Agent Instructions
This documentation is published with GitBook. GitBook is the documentation platform designed so that both humans and AI agents can read, navigate, and reason over technical content effectively. Learn more at gitbook.com.
## Querying This Documentation
If you need additional information that is not directly available in this page, you can query the documentation by asking a question.
Perform an HTTP GET request on the following URL with the `ask` and `goal` query parameters:
```
GET https://docs.petoi.com/mobile-app/app-guide/bittle-x+arm.md?ask=&goal=
```
`ask` is the immediate question: it should be specific, self-contained, and written in natural language.
`goal` is what the user is ultimately trying to achieve, the reason they need the answer. Sharing it helps GitBook give you a better, more relevant answer. A goal is most helpful when it describes the outcome the user wants rather than restating the question. For example, with `ask=how do I create an API token`, a goal like `automate deployments from our CI pipeline` lets GitBook tailor the answer to that use case.
The response will contain a direct answer to the question and relevant excerpts and sources from the documentation.
Use this mechanism when the answer is not explicitly present in the current page, you need clarification or additional context, or you want to retrieve related documentation sections.

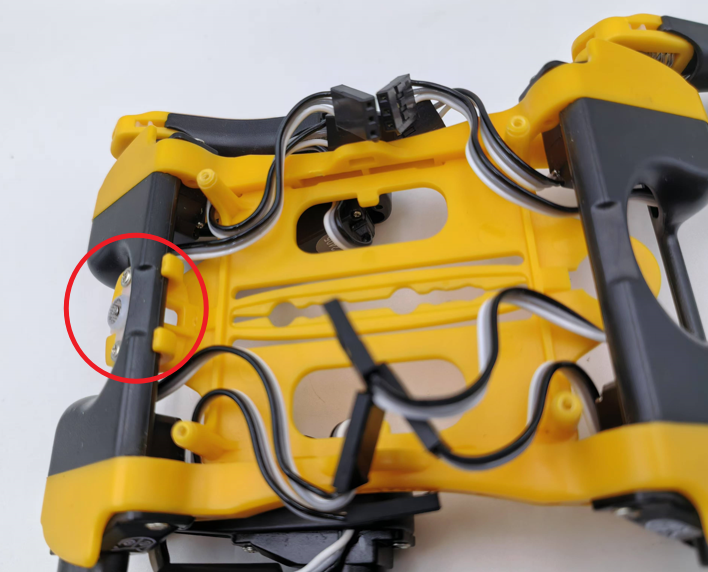 
{% endhint %}
Installing the neck servo is the same as [installing the head](/mobile-app/app-guide/bittle.md#install-the-head) of Bittle.
Installing the leg servos is the same as [installing the legs](/mobile-app/app-guide/bittle.md#install-the-legs) of Bittle.
### Install the robot arm
This robot arm is already fully assembled. After finishing calibrating the neck servo and the leg servos, power off the robot and [install](/extensible-modules/robot-arm.md#installation) the servo slot on the neck servo with two M2\*5 self-tapping screws.
Then, power on the robot, and do the joint calibration for the servos on the robot arm.
---
# Agent Instructions
This documentation is published with GitBook. GitBook is the documentation platform designed so that both humans and AI agents can read, navigate, and reason over technical content effectively. Learn more at gitbook.com.
## Querying This Documentation
If you need additional information that is not directly available in this page, you can query the documentation by asking a question.
Perform an HTTP GET request on the following URL with the `ask` and `goal` query parameters:
```
GET https://docs.petoi.com/mobile-app/app-guide/bittle-x+arm.md?ask=